部落格
北極熊導航復現日誌
本文由簡體中文內容確定性轉換,並受版本化術語表保護。
1.簡介
介紹:https://bbs.robomaster.com/wiki/4577/714072?source=7
原始碼1:https://github.com/SMBU-PolarBear-Robotics-Team/pb2025_sentry_nav 原始碼2:https://github.com/SMBU-PolarBear-Robotics-Team/rmu_gazebo_simulator
Fork:https://github.com/tungchiahui/ysu2026_rm_sentry
2.執行方式
2.1.demo
colcon build --symlink-install --cmake-args -DCMAKE_BUILD_TYPE=Release# 导航
ros2 launch pb2025_nav_bringup rm_navigation_simulation_launch.py \
world:=rmuc_2025 \
slam:=False# 启动仿真
ros2 launch rmu_gazebo_simulator bringup_sim.launch.py2.2.YSU
克隆程式碼:
git clone https://github.com/tungchiahui/ysu2026_rm_sentry.git安裝small_gicp:
sudo apt install -y libeigen3-dev libomp-dev

git clone https://github.com/koide3/small_gicp.git
cd small_gicp
mkdir build && cd build
cmake .. -DCMAKE_BUILD_TYPE=Release && make -j
sudo make install
安裝xmacro和vcstool2:
sudo apt install python3-pip python3-vcstool
pip install xmacro
安裝依賴:
cd ./ysu2026_rm_sentry

sudo apt update
rosdep install -r --from-paths src --ignore-src --rosdistro $ROS_DISTRO -y
colcon build --symlink-install3.功能包
3.1.ysu2026_robot_description
本功能包複製於pb2025_robot_description:
然後把packages.xml和cmakelists.txt裡的pb2025_robot_description全部改成ysu2026_robot_description。
把/src/ysu2026_robot_description/xmacro/pb2025_sentry_robot.sdf.xmacro複製一份為/src/ysu2026_robot_description/xmacro/ysu2026_sentry_robot.sdf.xmacro。
隨後刪掉pb2025_infantry_robot.sdf.xmacro和pb2025_sentry_robot.sdf.xmacro。
3.1.1.擴充套件知識點
3.1.1.1.xmacro
- 變數基本完全對應
xacro
<xacro:property name="wheel_radius" value="0.076"/>

<cylinder radius="${wheel_radius}" length="0.03"/>
xmacro
<xmacro_define_value name="wheel_radius" value="0.076"/>

<cylinder>
    <radius>${wheel_radius}</radius>
    <length>0.03</length>
</cylinder>- 巨集定義也幾乎一一對應
xacro
<xacro:macro name="wheel" params="name radius width">
    <link name="${name}">
        ...
    </link>
</xacro:macro>
呼叫:
<xacro:wheel
    name="front_left_wheel"
    radius="0.076"
    width="0.03"
/>
xmacro
<xmacro_define_block
    name="wheel"
    params="name radius width">

    <link name="${name}">
        ...
    </link>

</xmacro_define_block>
呼叫:
<xmacro_block
    name="wheel"
    name_arg="front_left_wheel"
    radius="0.076"
    width="0.03"
/>- include
xacro
<xacro:include filename="wheel.xacro"/>xmacro
<xmacro_include uri="file://wheel.sdf.xmacro"/>在當前專案中還可以看到:
<xmacro_include
    uri="model://rm25_example_robot/rm25_example_robot.def.xmacro"
/>這裡的model://是 sdformat_tools 針對 Gazebo / SDF 做的 URI 解析支援。
- ${} 表示式
xmacro 和 xacro 都支援類似:
${radius}以及數學表示式:
${2 * radius}例如:
<ixx>${m*(y*y+z*z)/12}</ixx>所以可以在宏引數中進行簡單數學運算。
- 條件
xacro
<xacro:if value="${use_lidar}">
    ...
</xacro:if>
xmacro
xmacro 中通常可以通過巨集呼叫的 condition 控制:
<xmacro_block
    name="lidar"
    condition="${use_lidar}"
    ...
/>
條件為真時展開這個宏,條件為假時不展開。
- .def.xmacro
例如:
rm25_example_robot.def.xmacro這裡的.def並不是 xmacro 的特殊語法,只是一種檔案命名習慣。
通常表示:這個檔案主要負責定義宏。
類似:
xxx.def.xmacro
    ↓
定义机器人结构、link、joint 等宏
然後:
simulation_robot.sdf.xmacro
    ↓
include 前面的 def.xmacro
    ↓
调用其中定义的宏
    ↓
生成完整 SDF
例如以後可以寫:
ysu2026_sentry_robot.def.xmacro裡面定義:
<xmacro_define_block
    name="ysu2026_sentry_robot"
    params="chassis_height gimbal_yaw_height">

    ...

</xmacro_define_block>
然後在:
simulation_robot.sdf.xmacro中引入並呼叫:
<xmacro_include
    uri="model://ysu2026_sentry_robot/ysu2026_sentry_robot.def.xmacro"
/>

<xmacro_block
    name="ysu2026_sentry_robot"
    chassis_height="${chassis_height}"
    gimbal_yaw_height="${gimbal_yaw_height}"
/>
記憶:
xmacro_define_value
    ≈ xacro:property

xmacro_define_block
    ≈ xacro:macro

xmacro_block
    ≈ 调用 xacro macro

xmacro_include
    ≈ xacro:include

${...}
≈ ${...}3.1.2.總體框架
3.1.2.1.xmacro介紹
這個xmacro是本專案裡自定義的一種格式,為了實現:
                  ┌→ SDF → Gazebo
.sdf.xmacro ──────┤
                  └→ SDF → URDF → robot_state_publisher
而之前學過的xacro+urdf,這個專案主要是xmacro+sdf。(對比著理解)
然後我們之前接觸的都是
robot.urdf.xacro
      ↓
    xacro
      ↓
robot_description
      ↓
robot_state_publisher
      ↓
TF
而這個專案是:
simulation_robot.sdf.xmacro
          ↓
      xmacro4sdf
          ↓
         SDF
       ↙     ↘
   Gazebo    sdf2urdf
                 ↓
               URDF
                 ↓
      robot_state_publisher
                 ↓
TF| 功能 | xacro | xmacro |
|---|---|---|
| 定義變數 | <xacro:property name="r" value="0.1"/> |
<xmacro_define_value name="r" value="0.1"/> |
| 使用變數 | ${r} |
${r} |
| 數學表示式 | ${2 * r} |
${2 * r} |
| 定義宏 | <xacro:macro name="wheel" params="r w"> |
<xmacro_define_block name="wheel" params="r w"> |
| 呼叫宏 | <xacro:wheel r="..." w="..."/> |
<xmacro_block name="wheel" r="..." w="..."/> |
| include | <xacro:include filename="xxx.xacro"/> |
<xmacro_include uri="file://xxx.xmacro"/> |
| 條件 | <xacro:if value="${...}">...</xacro:if> |
主要通過 <xmacro_block ... condition="${...}"/> |
| namespace | xmlns:xacro=... |
不需要 |
| 引數預設值等高階功能 | 較豐富 | 簡化很多 |
3.1.2.2.如何先建立自己的功能包和模型包
這個sdf.xmacro會被依賴去釋出模擬裡的模型和實物的tf關係。
這裡是include了下面這個檔案,所以要找這個檔案。
<xmacro_include uri="model://rm25_example_robot/rm25_example_robot.def.xmacro" />他在/src/rmoss_gz_resources/resource/models/rm25_example_robot裡,
你複製下這個大資料夾,並重命名為ysu2026_sentry_robot,裡面的xmacro也命名為ysu2026_sentry_robot.def.xmacro。
這個檔案裡面需要修改的是:
<!--macro defination: rm25_example_robot-->
<xmacro_define_block
    name="rm25_example_robot"
    params="sticker_type chassis_height gimbal_pitch_height gimbal_yaw_height">
把這裡的name改成
<!--macro definition: ysu2026_sentry_robot-->
<xmacro_define_block
    name="ysu2026_sentry_robot"
params="sticker_type chassis_height gimbal_pitch_height gimbal_yaw_height">接下來去修改同目錄的model.sdf.xmacro:
    <!--include defination-->
    <xmacro_include uri="model://rm25_example_robot/rm25_example_robot.def.xmacro" />

    <!--rm25_example_robot model-->
    <model name="rm25_example_robot">
        <pose>0 0 0.15 0 0 0</pose>
<xmacro_block name="rm25_example_robot" sticker_type="${global_armor_sticker_type}" chassis_height="${chassis_height}" gimbal_yaw_height="${gimbal_yaw_height}" gimbal_pitch_height="${gimbal_pitch_height}"/>把上面rm25_example_robot全部改成ysu2026_sentry_robot。
    <!--include defination-->
    <xmacro_include uri="model://ysu2026_sentry_robot/ysu2026_sentry_robot.def.xmacro" />

    <!--ysu2026_sentry_robot model-->
    <model name="ysu2026_sentry_robot">
        <pose>0 0 0.15 0 0 0</pose>
<xmacro_block name="ysu2026_sentry_robot" sticker_type="${global_armor_sticker_type}" chassis_height="${chassis_height}" gimbal_yaw_height="${gimbal_yaw_height}" gimbal_pitch_height="${gimbal_pitch_height}"/>接下來去修改同目錄的model.config:
<?xml version="1.0"?>
<model>
  <name>rmua19_standard_robot</name>
  <version>1.0</version>
  <sdf version="1.7">model.sdf</sdf>

  <author>
    <name>Lihan Chen</name>
    <email>lihanchen2004@163.com</email>
  </author>

  <description>
    The Basic Version of Standard Robot for RoboMaster University Series.
  </description>
</model>
修改成:
<?xml version="1.0"?>
<model>
  <name>ysu2026_sentry_robot</name>
  <version>1.0</version>
  <sdf version="1.7">model.sdf</sdf>

  <author>
    <name>Tung Chia-hui</name>
    <email>tungchiahui@gmail.com</email>
  </author>

  <description>
    Yanshan University RoboMaster 2026 Sentry Robot.
  </description>
</model>這裡的model.sdf不需要手動改,這玩意是自動生成的:
model.sdf.xmacro
      ↓
xmacro4sdf
      ↓
model.sdf你可以看看model.sdf開頭,明確說了這件事,而且不建議你直接修改:
<!-- =================================================================================== -->
<!-- |    This document was autogenerated by xmacro4sdf from model.sdf.xmacro          | -->
<!-- |    EDITING THIS FILE BY HAND IS NOT RECOMMENDED                                 | -->
<!-- =================================================================================== -->
所以以後真正維護的是:
关于模型:
ysu2026_sentry_robot.def.xmacro
model.sdf.xmacro

关于(这个不改问题也不大):
model.config回到/src/ysu2026_robot_description/resource/xmacro/ysu2026_sentry_robot.sdf.xmacro:
    <!--include defination-->
    <xmacro_include uri="model://rm25_example_robot/rm25_example_robot.def.xmacro" />

    <!--pb2025_sentry_robot model-->
    <model name="pb2025_sentry_robot">

        <pose>0 0 0.15 0 0 0</pose>
<xmacro_block name="rm25_example_robot" sticker_type="${global_armor_sticker_type}" chassis_height="${chassis_height}" gimbal_yaw_height="${gimbal_yaw_height}" gimbal_pitch_height="${gimbal_pitch_height}"/>把裡面的rm25_example_robot和pb2025_sentry_robot全改成ysu2026_sentry_robot:
    <!--include defination-->
    <xmacro_include uri="model://ysu2026_sentry_robot/ysu2026_sentry_robot.def.xmacro" />

    <!--ysu2026_sentry_robot model-->
    <model name="ysu2026_sentry_robot">

        <pose>0 0 0.15 0 0 0</pose>
<xmacro_block name="ysu2026_sentry_robot" sticker_type="${global_armor_sticker_type}" chassis_height="${chassis_height}" gimbal_yaw_height="${gimbal_yaw_height}" gimbal_pitch_height="${gimbal_pitch_height}"/>至此上面這些在reality環境下已經正常了,但simulation還不行,開啟同目錄下的simulation_robot.sdf.xmacro:
    <!--include defination-->
    <xmacro_include uri="model://rm25_example_robot/rm25_example_robot.def.xmacro" />

    <!--simulation_robot model-->
    <model name="simulation_robot">

        <pose>0 0 0.15 0 0 0</pose>
        <xmacro_block name="rm25_example_robot" sticker_type="${global_armor_sticker_type}" chassis_height="${chassis_height}" gimbal_yaw_height="${gimbal_yaw_height}" gimbal_pitch_height="${gimbal_pitch_height}"/>
改成:
    <!--include defination-->
    <xmacro_include uri="model://ysu2026_sentry_robot/ysu2026_sentry_robot.def.xmacro" />

    <!--simulation_robot model-->
    <model name="simulation_robot">

        <pose>0 0 0.15 0 0 0</pose>
        <xmacro_block name="ysu2026_sentry_robot" sticker_type="${global_armor_sticker_type}" chassis_height="${chassis_height}" gimbal_yaw_height="${gimbal_yaw_height}" gimbal_pitch_height="${gimbal_pitch_height}"/>
至此,你就修改完了。
grep -R "rm25_example_robot" src/ysu2026_robot_description src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot

grep -R "pb2025_sentry_robot" src/ysu2026_robot_description src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot
正常應該是:
root@Desktop-Fedora:/home/tungchiahui/UserFolder/MySource/ysu2026_rm_sentry$ grep -R "rm25_example_robot" src/ysu2026_robot_description src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot
src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot/model.sdf:  <!--rm25_example_robot model-->
src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot/model.sdf:  <model name="rm25_example_robot">
root@Desktop-Fedora:/home/tungchiahui/UserFolder/MySource/ysu2026_rm_sentry$ grep -R "pb2025_sentry_robot" src/ysu2026_robot_description src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot只有model.sdf裡還有殘留:
找到這個指令碼:/src/rmoss_gz_resources/update_model.sh
#!/bin/bash
path=`pwd`
for dir in $path/models/*; do
    echo "parse "$dir
    cd $dir
    tempfile=`mktemp temp.XXXXXX`
    xmacro4sdf model.sdf.xmacro > $tempfile
    lines_num=`cat $tempfile | wc -l`
    if (($lines_num > 3 )) ;then
        cat $tempfile > model.sdf
    else
        cat $tempfile
    fi
    rm -f temp.*
done
修改為:
#!/bin/bash

SCRIPT_DIR="$(cd "$(dirname "${BASH_SOURCE[0]}")" && pwd)"
MODEL_DIR="$SCRIPT_DIR/resource/models"

# 让 xmacro4sdf 能解析 model://xxx/...
export IGN_GAZEBO_RESOURCE_PATH="$MODEL_DIR:${IGN_GAZEBO_RESOURCE_PATH:-}"
export GAZEBO_MODEL_PATH="$MODEL_DIR:${GAZEBO_MODEL_PATH:-}"

for dir in "$MODEL_DIR"/*; do
    [ -d "$dir" ] || continue
    [ -f "$dir/model.sdf.xmacro" ] || continue

    echo "parse $dir"

    cd "$dir" || exit 1

    tempfile=$(mktemp temp.XXXXXX)

    if xmacro4sdf model.sdf.xmacro > "$tempfile"; then
        lines_num=$(wc -l < "$tempfile")

        if (( lines_num > 3 )); then
            cat "$tempfile" > model.sdf
            echo "generated: $dir/model.sdf"
        else
            echo "ERROR: generated content too short"
            cat "$tempfile"
        fi
    else
        echo "ERROR: xmacro4sdf failed: $dir"
    fi

    rm -f "$tempfile"
done
執行:
chmod +x ./src/rmoss_gz_resources/update_model.sh
./src/rmoss_gz_resources/update_model.sh
生成完後,返回ws目錄:
grep -R "rm25_example_robot" src/ysu2026_robot_description src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot會發現也沒有輸出了。
3.1.2.3.修改機器人引數
主要是機器人的底盤長寬、輪距/軸距、輪徑、雲臺高度、Mid360 安裝位置:
1. 底盘长宽高 / collision
2. 四个轮子的位置
3. 轮子半径
4. chassis_height
5. gimbal_yaw_height
6. gimbal_pitch_height
7. Mid360 的 parent 和 pose
首先你得知道ROS預設規定的方向:
+x:车头方向
+y:车体左侧
+z:竖直向上
而且北極熊現在的模型裡,base_footprint 在地面,chassis 原點基本位於四個輪子的輪軸中心高度。
| 引數 | 你實際應該量什麼 | 當前程式碼含義 |
|---|---|---|
| 底盤長度 | 車體剛性主體前沿到後沿,沿 X | geometry_box x=... |
| 底盤寬度 | 車體剛性主體左沿到右沿,沿 Y | geometry_box y=... |
| 底盤高度 | 剛性主體底面到頂面,沿 Z | geometry_box z=... |
| 軸距 | 前輪軸心到後輪軸心的 X 向距離 | x_front - x_rear |
| 輪距 | 左輪中心面到右輪中心面的 Y 向距離 | y_left - y_right |
| 輪徑 | 輪子外圓直徑 | 當前 2 × 0.0758 |
chassis_height |
地面 → chassis 座標系原點 |
當前 0.076 m |
gimbal_yaw_height |
chassis 原點 → 雲臺 yaw 旋轉軸原點 |
當前 0.1376 m |
gimbal_pitch_height |
yaw 軸原點 → pitch 軸原點 | 當前 0.16 m |
Mid360 pose |
parent 座標系原點 → front_mid360 原點 |
當前相對 chassis |
開啟/src/ysu2026_robot_description/resource/xmacro/ysu2026_sentry_robot.sdf.xmacro
主要修改下面幾個:
- 底盤長度和底盤寬度
底盤長寬和軸距/輪距不是一個東西
比如現在北極熊:
        <!--chassis-->
        <link name="chassis">
            <inertial>
                <pose>0 0 0.055 0 0 0</pose>
                <xmacro_block name="inertia_box" m="15.0" x="0.36" y="0.24" z="0.13"/>
底盘 collision:
长度 x = 0.36
宽度 y = 0.24
但:
轴距 = 0.414
轮距 = 0.388
所以以後你可能得到:
底盘主体:
长 360 mm
宽 300 mm

轮中心:
轴距 420 mm
轮距 390 mm- 底盤高度
這個引數如其字面意思一樣,就是底盤的厚度,也就是底盤的上頂面到下底面的距離。
- 軸距和輪距也要量“輪中心”,不是底盤外殼
北極熊的是:
找到/src/rmoss_gz_resources/resource/models/ysu2026_sentry_robot:
        <!--front_left wheel link and joint-->
        <xmacro_block name="chassis_wheel_l" prefix="front_left" parent="chassis" pose="0.207 0.194 0 0 0 0"/>
        <!--front_right wheel link and joint-->
        <xmacro_block name="chassis_wheel_r" prefix="front_right" parent="chassis" pose="0.207 -0.194 0 0 0 0"/>
        <!--rear_left wheel link and joint-->
        <xmacro_block name="chassis_wheel_r" prefix="rear_left" parent="chassis" pose="-0.207 0.194 0 0 0 0"/>
        <!--rear_right wheel link and joint-->
        <xmacro_block name="chassis_wheel_l" prefix="rear_right" parent="chassis" pose="-0.207 -0.194 0 0 0 0"/>
FL: 0.207 0.194
FR: 0.207 -0.194
RL: -0.207 0.194
RR: -0.207 -0.194那麼軸距是 = 0.207 - (-0.207) = 0.414 m
那麼輪距是 = 0.194 - (-0.194) = 0.388 m
示意圖:
                 +X 前

       FL ●────────────● FR
          │            │
          │            │
          │            │
          │            │
       RL ●────────────● RR

          ←  轮距  →

前后两个轮轴中心的距离
        = 轴距
所以要測量的資料是: 前左輪中心 到 後左輪中心:X 方向距離 左輪中心面 到 右輪中心面:Y 方向距離 不是量輪胎最外側。
- 輪徑
這是輪子的直徑,不是半徑,注意下。
- 底盤距離水平地面的高度chassis_height:
    <!-- 底盘距离水平地面的高度 -->
    <xmacro_define_value name="chassis_height" value="0.077" />
    <!-- gimbal_yaw 相对于底盘的 z 轴安装偏移 -->
    <xmacro_define_value name="gimbal_yaw_height" value="0.026" />
    <!-- gimbal_pitch 相对于 gimbal_yaw 的高度差 -->
<xmacro_define_value name="gimbal_pitch_height" value="0.355" />這裡的幾個引數,這裡的chassis_height所描述的是:
<joint name="base_to_chassis" type="fixed">
    <pose>0 0 ${chassis_height} 0 0 0</pose>
    <parent>base_footprint</parent>
    <child>chassis</child>
</joint>
由於四個輪子的 joint 都是:
parent="chassis"
pose="... ... 0 0 0 0"
所以結構其實是:
          chassis 原点
               ●──────── 轮轴中心(一般来讲是底盘原点,正好这个是轮轴中心重合了)
               │
               │ chassis_height
               │
地面 ──────────●──────────
base_footprint- 雲臺高度gimbal_yaw_height
<pose relative_to='chassis'>
    0 0 ${gimbal_yaw_height} 0 0 0
</pose>
他描述的是
chassis 坐标系原点
        │
        │ gimbal_yaw_height
        │
        ▼
云台 yaw 旋转轴原点
也就是chassis 座標系原點到 yaw 旋轉軸中心的 Z 向距離。
如果雲臺相對於底盤有前後偏移,那麼不能只填gimbal_yaw_height,應該填完整的pose。
- 雲臺高度gimbal_pitch_height
也就是 yaw 旋轉軸中心 → pitch 旋轉軸中心的垂直距離。
                    ● pitch 旋转轴
                    │
                    │ gimbal_pitch_height
                    │
                    ● yaw 旋转轴
                    │
                    │ gimbal_yaw_height
                    │
                    ● chassis 原点
                    │
                    │ chassis_height
                    │
────────────────────● 地面-
mid360
- mid360的原點:
規定的方向:
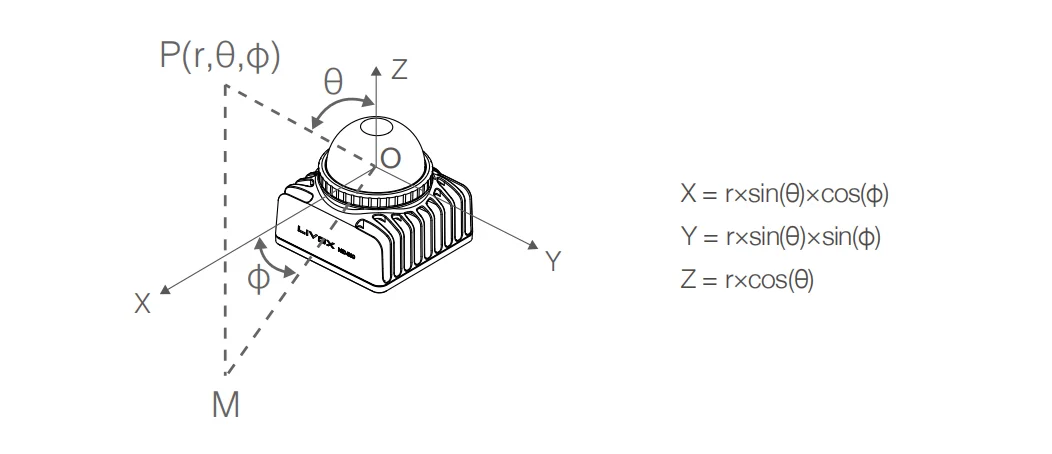
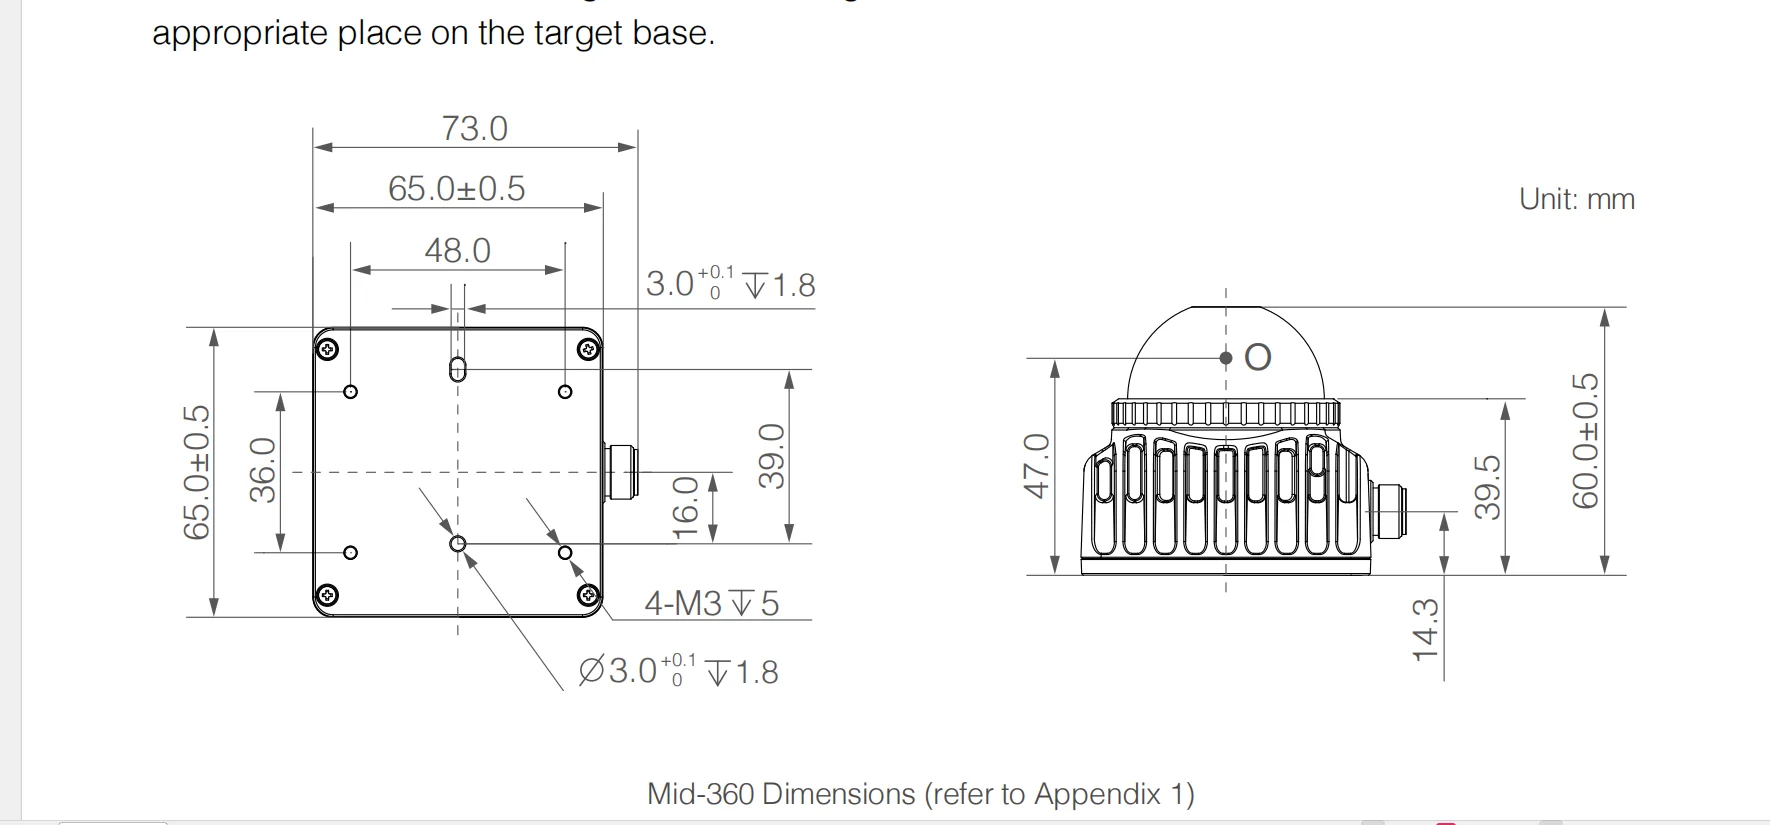
如上圖可知,位於雷射雷達的中心軸上,並距離底面47mm處。
也就是
底部安装面中心
    │
    │ +47 mm
    ↓
   O 点
先量 chassis / 雲臺座標原點 到 Mid360 底部安裝面中心的位置,然後 Z 再補這 47 mm,就能得到 chassis / 雲臺 → Mid360 官方 O 點的位置。
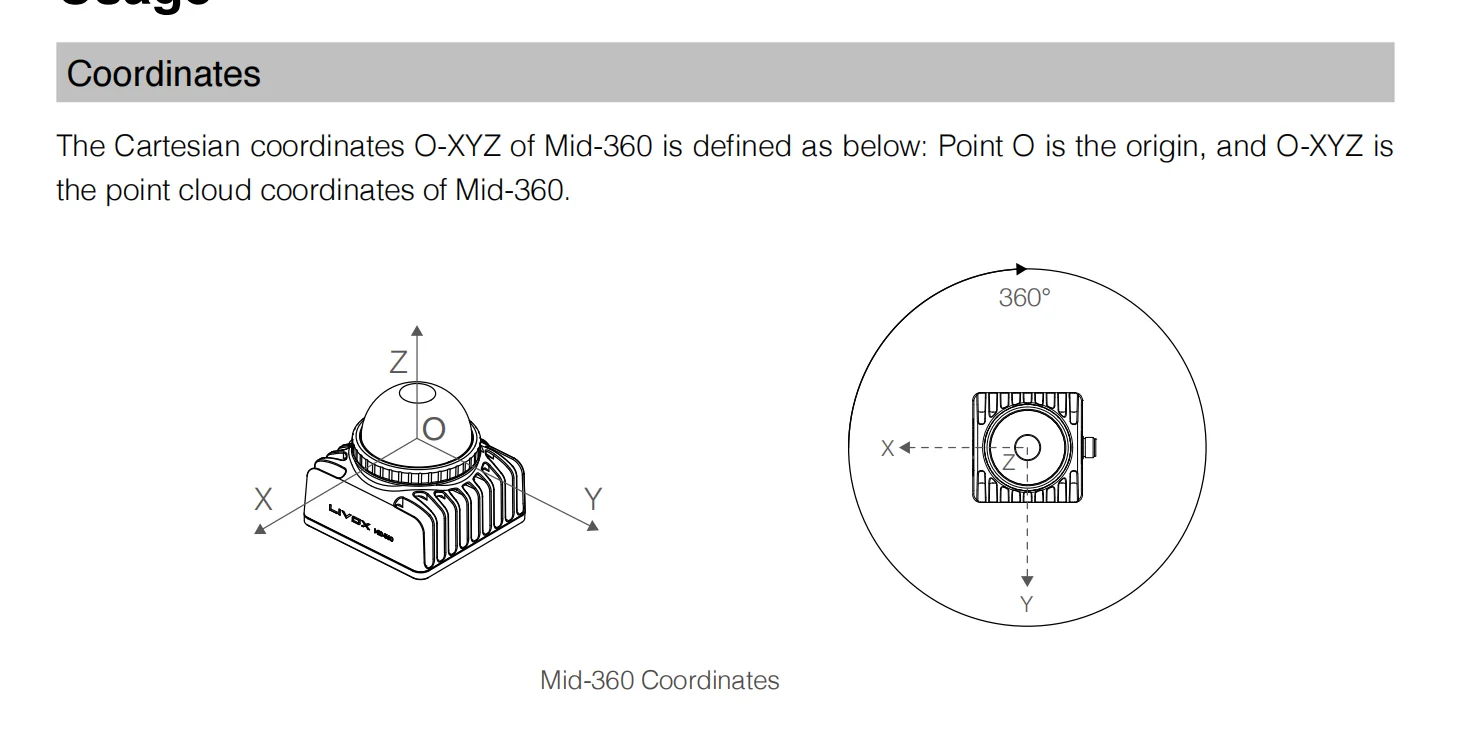
官方說明:
官方手冊明確規定:Mid-360 的 O-XYZ 是點雲座標系,其中 O 是點雲原點。
而內建 IMU 晶片相對於這個點雲座標系的位置是:
x = +11.00 mm
y = +23.29 mm
z = -44.12 mm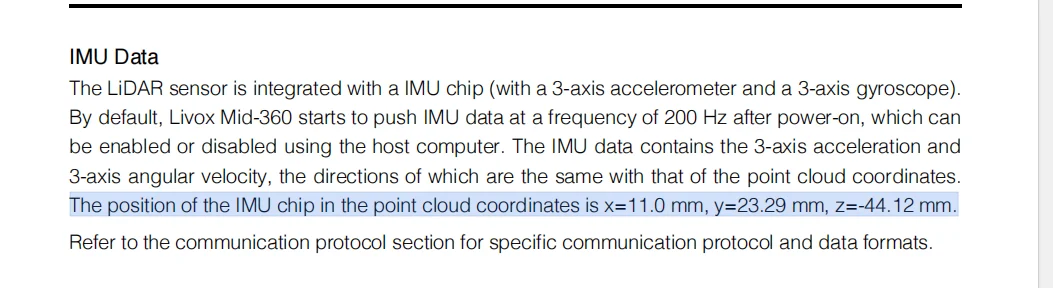
front_mid360 = LiDAR 点云 O 点
        ●
        │
        │  (+11, +23.29, -44.12) mm
        │
        ● IMU 芯片原点
這裡先提前說明下``front_mid360`就是雷達的O_XYZ原點,具體怎麼推出來的,請往下看。
- mid360的pose
<!--livox--> <xmacro_block name="livox" prefix="front_" parent="chassis" pose="0.16 0.0 0.18 ${pi/6} 0.0 ${pi/2}" ... />- 這個 pose 是 : chassis 座標系 → front_mid360 座標系
- 按北極熊這個來,是嚴格相對於 chassis 原點。
- 他的雷達是裝在底盤上的,所以
parent="chassis",如果雷達要裝在雲臺,就改成parent="gimbal_yaw",那麼偏移也會變成相對於gimbal_yaw座標系的偏移。.
x = +0.16 m
y =  0
z = +0.18 m
意思是 Mid360 O原點相對於 chassis 原點:
向前 160 mm
左右不偏
向上 180 mm
他這裡pose的後三個引數是RPY,也就是相對於chassis 原點的偏移:
roll  = π/6 = 30°
pitch = 0°
yaw   = π/2 = 90°
另外你在 Mid360 model 裡還會看到:
<visual>
    <pose>0 0 0 0 0 ${pi}</pose>
這個只是外觀 mesh 轉了 180°,不等於雷達感測器 frame 轉了 180°。不要拿這個來算 TF。
- mid360到底量它外殼哪個點?
這裡還要再精確一層。 北極熊當前 Mid360 模型內部是:
<joint ...>
    <child>${prefix}mid360</child>
</joint>

<link name="${prefix}mid360">
這裡的
${prefix}mid360會被解析為front_mid360:這個
front_mid360一直很懵逼,他到底是什麼? 他在readme裡寫的模擬裡是簡化的,所以不要在模擬裡反推這個座標系的原點到底是什麼? 在reality的Point LIO裡你可以看到extrinsic_T: [-0.011, -0.02329, 0.04412],這正是官方IMU的偏移。 而frame_id = front_mid360,所以說,反推出來front_mid360是我們點雲的座標系,也就是O_XYZ.而北極熊的 LiDAR 光學/掃描感測器實際上還額外:
<sensor name="${prefix}mid360_lidar" ...>
<pose>0 0 0.03 0 0 0</pose>
front_mid360 link 原点 │ │ +30 mm ▼ LiDAR 扫描原点而 IMU:
<sensor name="${prefix}mid360_imu" type="imu">沒有額外 pose,所以當前模擬裡基本相當於:IMU 原點 = front_mid360 原點
- mid360最後各個資料究竟填什麼?
front_mid360為mid360的O_XYZ的原點。那麼Mid360官方點雲原點就和O_XYZ原點重合。 那麼Mid360官方IMU原點就和O_XYZ有(+11, +23.29, -44.12)mm的偏移量。(但這裡沒必要給pose,在point_lio裡給pose即可)
所以
<!-- chassis -> Mid360 官方点云 O -->
<xmacro_block
    name="livox"
    prefix="front_"
    parent="chassis"
    pose="实际 x 实际 y 实际 z 实际 roll 实际 pitch 实际 yaw"
/>
然後 Mid360 模擬內部:
<sensor name="${prefix}mid360_lidar" type="gpu_lidar">
<pose>0 0 0 0 0 0</pose>
而IMU這邊,北極熊的方案我看懂了,雖然他讓IMU座標系與點雲座標系直接重合,並且模擬裡也是重合的。 而在reality裡,他是
extrinsic_T: [-0.011, -0.02329, 0.04412],這裡明顯是已經考慮到了這個偏移,所以我們沒必要修改IMU的座標系偏移。
綜上,你應該需要的資料是:
1. 轮子实际直径

2. 前后轮中心轴距
   前轮中心 → 后轮中心

3. 左右轮中心轮距
   左轮中心面 → 右轮中心面

4. chassis 刚性主体:
   X 方向长度
   Y 方向宽度
   Z 方向高度

5. chassis/轮轴中心 → 云台 yaw 旋转轴中心:
   Δx
   Δy
   Δz

   如果云台不在底盘正中央,x/y 也得知道。

6. yaw 旋转轴中心 → 云台 pitch 旋转轴中心:
   Δx
   Δy
   Δz

7. Mid360 如果挂 chassis:
   chassis 原点 → Mid360 reference frame(mid360的原点:距离底面中心高47mm处)
   Δx Δy Δz
   roll pitch yaw

   如果挂 gimbal_yaw:
   yaw 轴原点 → Mid360 reference frame(mid360的原点:距离底面中心高47mm处)
   Δx Δy Δz
roll pitch yaw3.2.把各種功能包裡的launch全部修改了
修改launch重定向到咱們的模型,主要先看下面的launch:
-
pb2025_nav_bringup裡的rm_navigation_simulation_launch.py- 同功能包下的
robot_state_publisher_launch.py
- 同功能包下的
-
rmu_gazebo_simulator裡的bringup_sim.launch.py- 同功能包下的
spawn_robots.launch.py - 同功能包下的
package.xml
- 同功能包下的
-
ysu2026_robot_description裡的robot_description_launch.py
3.2.1.robot_state_publisher_launch.py:
    pkg_pb2025_robot_description_dir = get_package_share_directory(
        "pb2025_robot_description"
    )

    declare_robot_name_cmd = DeclareLaunchArgument(
        "robot_name",
        default_value="pb2025_sentry_robot",
        description="The file name of the robot xmacro to be used",
    )
改成
    pkg_robot_description_dir = get_package_share_directory(
        "ysu2026_robot_description"
    )

    declare_robot_name_cmd = DeclareLaunchArgument(
        "robot_name",
        default_value="ysu2026_sentry_robot",
        description="The file name of the robot xmacro to be used",
)3.2.2.spawn_robots.launch.py:
    pkg_pb2025_robot_description = get_package_share_directory(
        "pb2025_robot_description"
    )

    robot_xmacro_path = os.path.join(
        pkg_pb2025_robot_description,
        "resource",
        "xmacro",
        "simulation_robot.sdf.xmacro",
    )
改成:
    pkg_robot_description = get_package_share_directory(
        "ysu2026_robot_description"
    )

    robot_xmacro_path = os.path.join(
        pkg_robot_description,
        "resource",
        "xmacro",
        "simulation_robot.sdf.xmacro",
)3.2.3.robot_description_launch.py:
def generate_launch_description():
    # Get the launch directory
    bringup_dir = get_package_share_directory("pb2025_robot_description")
改成
def generate_launch_description():
    # Get the launch directory
bringup_dir = get_package_share_directory("ysu2026_robot_description")3.2.4.rmu_gazebo_simulator裡的package.xml
<depend>pb2025_robot_description</depend>改成
<depend>ysu2026_robot_description</depend>3.2.5.測試
rm -rf build install log
colcon build --symlink-install
source install/setup.bash
ros2 launch rmu_gazebo_simulator bringup_sim.launch.pysource install/setup.bash
ros2 launch pb2025_nav_bringup rm_navigation_simulation_launch.py \
world:=rmuc_2025 \
slam:=False測試下Gazebo載入模型還正常不,如果正常則說明沒毛病。
至此全部結束。
3.3.ysu2026_robot_description修改掉mid360的位置
北極熊的雷達是放在底盤上的,我們準備放到Yaw雲臺上。
        <!--livox-->
        <xmacro_block name="livox" prefix="front_" parent="chassis" pose="0.0496 0.0936 0.435 -${pi/12} 0 0" update_rate="20" samples="1875"/>
這代表:
chassis
└── front_mid360只需要改掉parent="chassis"即可。
我們想要的TF鏈是:
chassis
  │
  │ gimbal_yaw_odom_joint = joint_yaw
  ▼
gimbal_yaw_odom
  │
  │ fixed
  ▼
gimbal_pitch_odom
  │
  │ gimbal_yaw_joint = 0
  ▼
gimbal_yaw
  │
  │ gimbal_pitch_joint = joint_pitch
  ▼
gimbal_pitch如果沒有什麼大Yaw小Yaw雲臺,那麼掛在gimbal_yaw_odom和gimbal_yaw沒有任何區別,都不會影響導航。
但是,由於沒有什麼大Yaw小Yaw雲臺,然後還要根據robot_description釋出靜態TF,所以肯定是掛在gimbal_yaw_odom更加合理。
(但如果gimbal_yaw_odom和gimbal_yaw重合,那其實掛在哪都一樣)
chassis
  │
  │ joint_yaw
  ▼
gimbal_yaw_odom
  ├── front_mid360
  │
  └── ...
<!--livox-->
<xmacro_block name="livox" prefix="front_" parent="gimbal_yaw_odom" pose="0.0496 0.0936 0.435 -${pi/12} 0 0" update_rate="20" samples="1875"/>3.4.Serial_Comm
https://github.com/tungchiahui/Serial_Pack
可以參考序列埠驅動與序列埠包協議
3.5.Joy
可以參考Joy
然後搞兩個launch.py。
一個joy_controller.launch.py是用來發/cmd_vel的。(實車用的是這個)
一個joy_controller_sim.launch.py是用來發/red_standard_robot1/cmd_vel的。(模擬用的是這個)
3.6.MCU到Linux的資料
3.6.1.總概
chassis
  │
  ├─ gimbal_yaw_odom_joint      绕 Z,可动
  ▼
gimbal_yaw_odom
  │
  ├─ gimbal_pitch_odom_joint    fixed
  ▼
gimbal_pitch_odom
  │
  ├─ gimbal_yaw_joint           绕 Z,可动
  ▼
gimbal_yaw
  │
  ├─ gimbal_pitch_joint         绕 Y,可动
  ▼
gimbal_pitch
北極熊官方導航 README 明確把實車序列埠提供的關節稱為:
gimbal_yaw_odom   = 大 yaw
gimbal_yaw        = 小 yaw
gimbal_pitch      = pitch
gimbal_pitch_odom_joint:可以認為就是 0,因為你現在的 description 裡它本來就是 fixed。 gimbal_yaw_odom_joint:上電那一刻可以是 0,但執行時不能固定為 0,前提是咱們有北極熊同樣的“大 yaw”機構。它應該跟著大 yaw 的真實角度更新。
| joint | 當前模型型別 | 北極熊程式碼裡填的資料 | 可以理解成 |
|---|---|---|---|
gimbal_yaw_odom_joint |
revolute | ReceiveJointState.yaw |
雲臺/IMU 的參考 yaw 相對 chassis |
gimbal_pitch_odom_joint |
fixed | ReceiveJointState.pitch |
參考 pitch 層,但當前模型實際上固定 |
gimbal_yaw_joint |
revolute | IMU yaw |
IMU 相對於參考姿態的 yaw |
gimbal_pitch_joint |
revolute | IMU pitch |
IMU 相對於參考姿態的 pitch |
北極熊官方 standard_robot_pp_ros2 實際上有兩類 MCU→Linux 資料。
第一類是 IMU 資料:
yaw,pitch,roll然後Linux 收到以後,釋出 sensor_msgs/msg/Imu。
但其實這個資料沒啥用,北極熊並沒在導航裡用到roll,rpy_vel這些資料。
imu_state

roll       rad
pitch      rad
yaw        rad

roll_vel   rad/s
pitch_vel  rad/s
yaw_vel    rad/s
然後 pitch → gimbal_pitch_joint yaw → gimbal_yaw_joint
第二類是 JointState/雲臺參考位置資料:
這個很重要
joint_state

pitch_odom   rad
yaw_odom     rad
Linux 收到以後並不馬上釋出,而是儲存:
last_gimbal_pitch_odom_joint_ = pitch_odom;
last_gimbal_yaw_odom_joint_   = yaw_odom;
下一次 IMU 資料到來時,北極熊一次釋出完整四項:
joint_msg.name = {
    "gimbal_pitch_joint",
    "gimbal_yaw_joint",
    "gimbal_pitch_odom_joint",
    "gimbal_yaw_odom_joint",
};

joint_msg.position = {
    imu_pitch,
    imu_yaw,
    pitch_odom,
    yaw_odom,
};
但是咱們沒有大小yaw結構的話:
但為了儘量不改北極熊後面的 TF / Nav2 框架,最合適的相容方法是:
你们真实 yaw
    ↓
gimbal_yaw_odom_joint

不存在的小 yaw
    ↓
gimbal_yaw_joint = 0

你们真实 pitch
    ↓
gimbal_pitch_joint
chassis
│
│ gimbal_yaw_odom_joint = 实际 yaw(大yaw)
▼
gimbal_yaw_odom
│
│ gimbal_pitch_odom_joint = fixed
▼
gimbal_pitch_odom
│
│ gimbal_yaw_joint = 0 (不存在小yaw)
▼
gimbal_yaw
│
│ gimbal_pitch_joint = 实际 pitch
▼
gimbal_pitch msg_jointstate.name = {
"gimbal_pitch_joint", // 小pitch
"gimbal_yaw_joint", //小yaw
"gimbal_pitch_odom_joint", //fixed
"gimbal_yaw_odom_joint" //大yaw
};
msg_jointstate.position = {
pitch, // 真实 pitch
0.0, // 不存在的小 yaw
0.0, // fixed
yaw // 真实 yaw
};chassis
│
│ gimbal_yaw_odom_joint ← 大 yaw,动态
▼
gimbal_yaw_odom
│
│ gimbal_pitch_odom_joint ← fixed
▼
gimbal_pitch_odom
│
│ gimbal_yaw_joint ← 小 yaw,动态
▼
gimbal_yaw
│
│ gimbal_pitch_joint ← pitch,动态
▼
gimbal_pitch最後 chassis → gimbal_yaw 依然完全正確。
綜上,咱們正真需要的是:
MCU → Linux

roll       rad
pitch      rad
yaw        rad
joint_yaw  rad
joint_pitch rad
其中雲臺 IMU 的 RPY 用來生成 /serial/imu 的 orientation。
雲臺電機返回的角度用來joint_yaw和joint_pitch。
但其實,如果你的雷達放在Yaw的雲臺上,其實joint_pitch無所謂,不影響最終的導航,但可能和自瞄有關係。
檢視sensor_msgs/msg/JointState:
ros2 interface show sensor_msgs/msg/JointState# This is a message that holds data to describe the state of a set of torque controlled joints.
#
# The state of each joint (revolute or prismatic) is defined by:
# * the position of the joint (rad or m),
# * the velocity of the joint (rad/s or m/s) and
# * the effort that is applied in the joint (Nm or N).
#
# Each joint is uniquely identified by its name
# The header specifies the time at which the joint states were recorded. All the joint states
# in one message have to be recorded at the same time.
#
# This message consists of a multiple arrays, one for each part of the joint state.
# The goal is to make each of the fields optional. When e.g. your joints have no
# effort associated with them, you can leave the effort array empty.
#
# All arrays in this message should have the same size, or be empty.
# This is the only way to uniquely associate the joint name with the correct
# states.
std_msgs/Header header
builtin_interfaces/Time stamp
int32 sec
uint32 nanosec
string frame_id
string[] name
float64[] position
float64[] velocity
float64[] effort